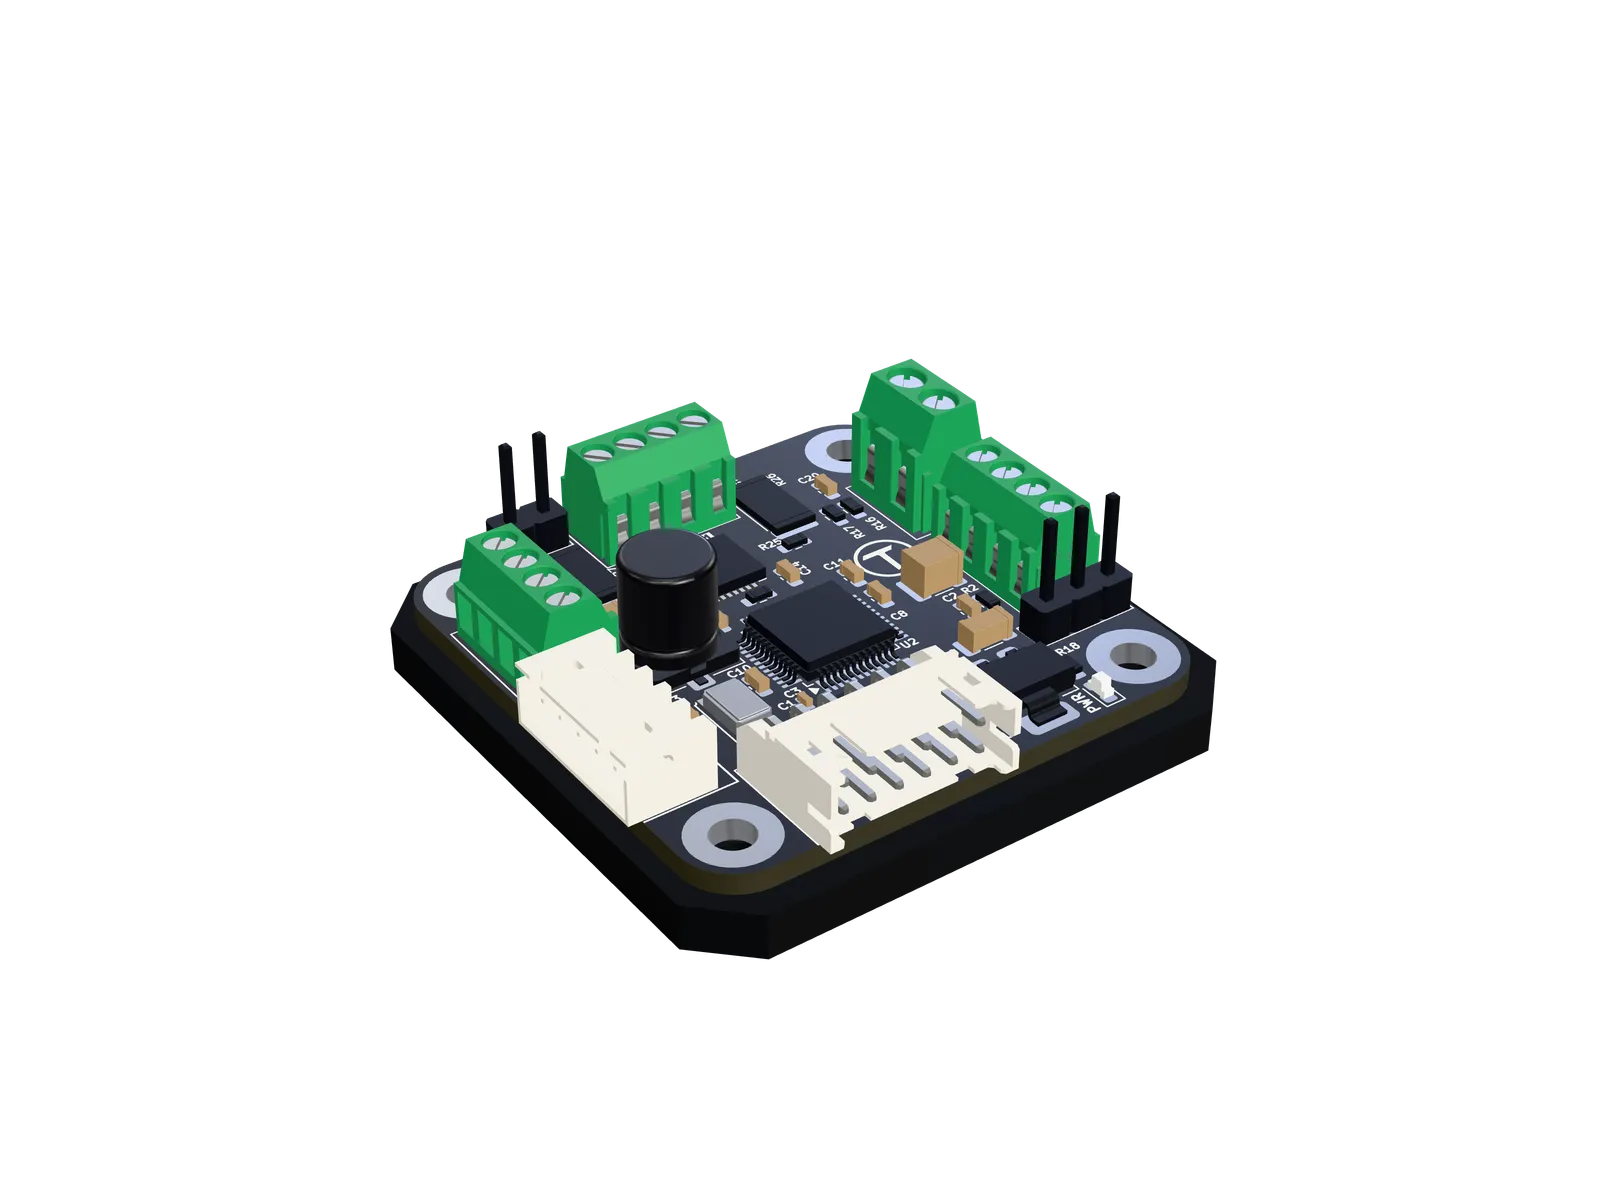
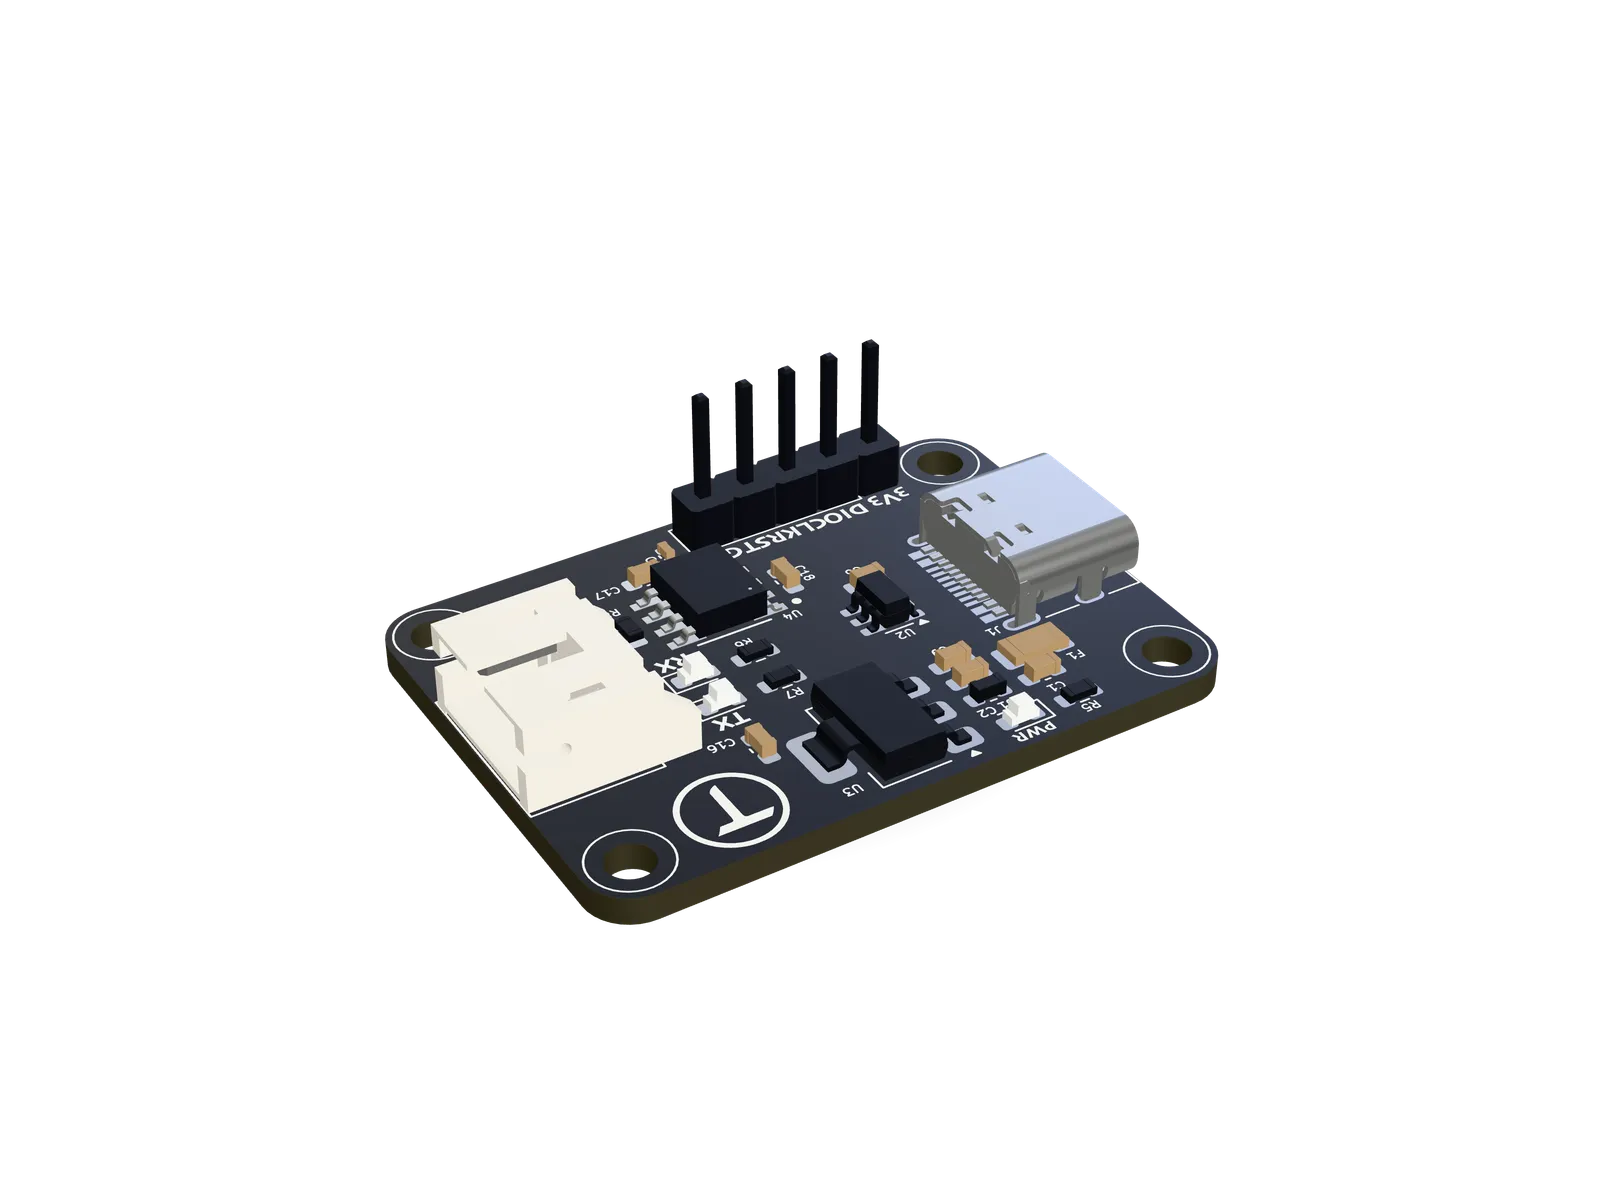
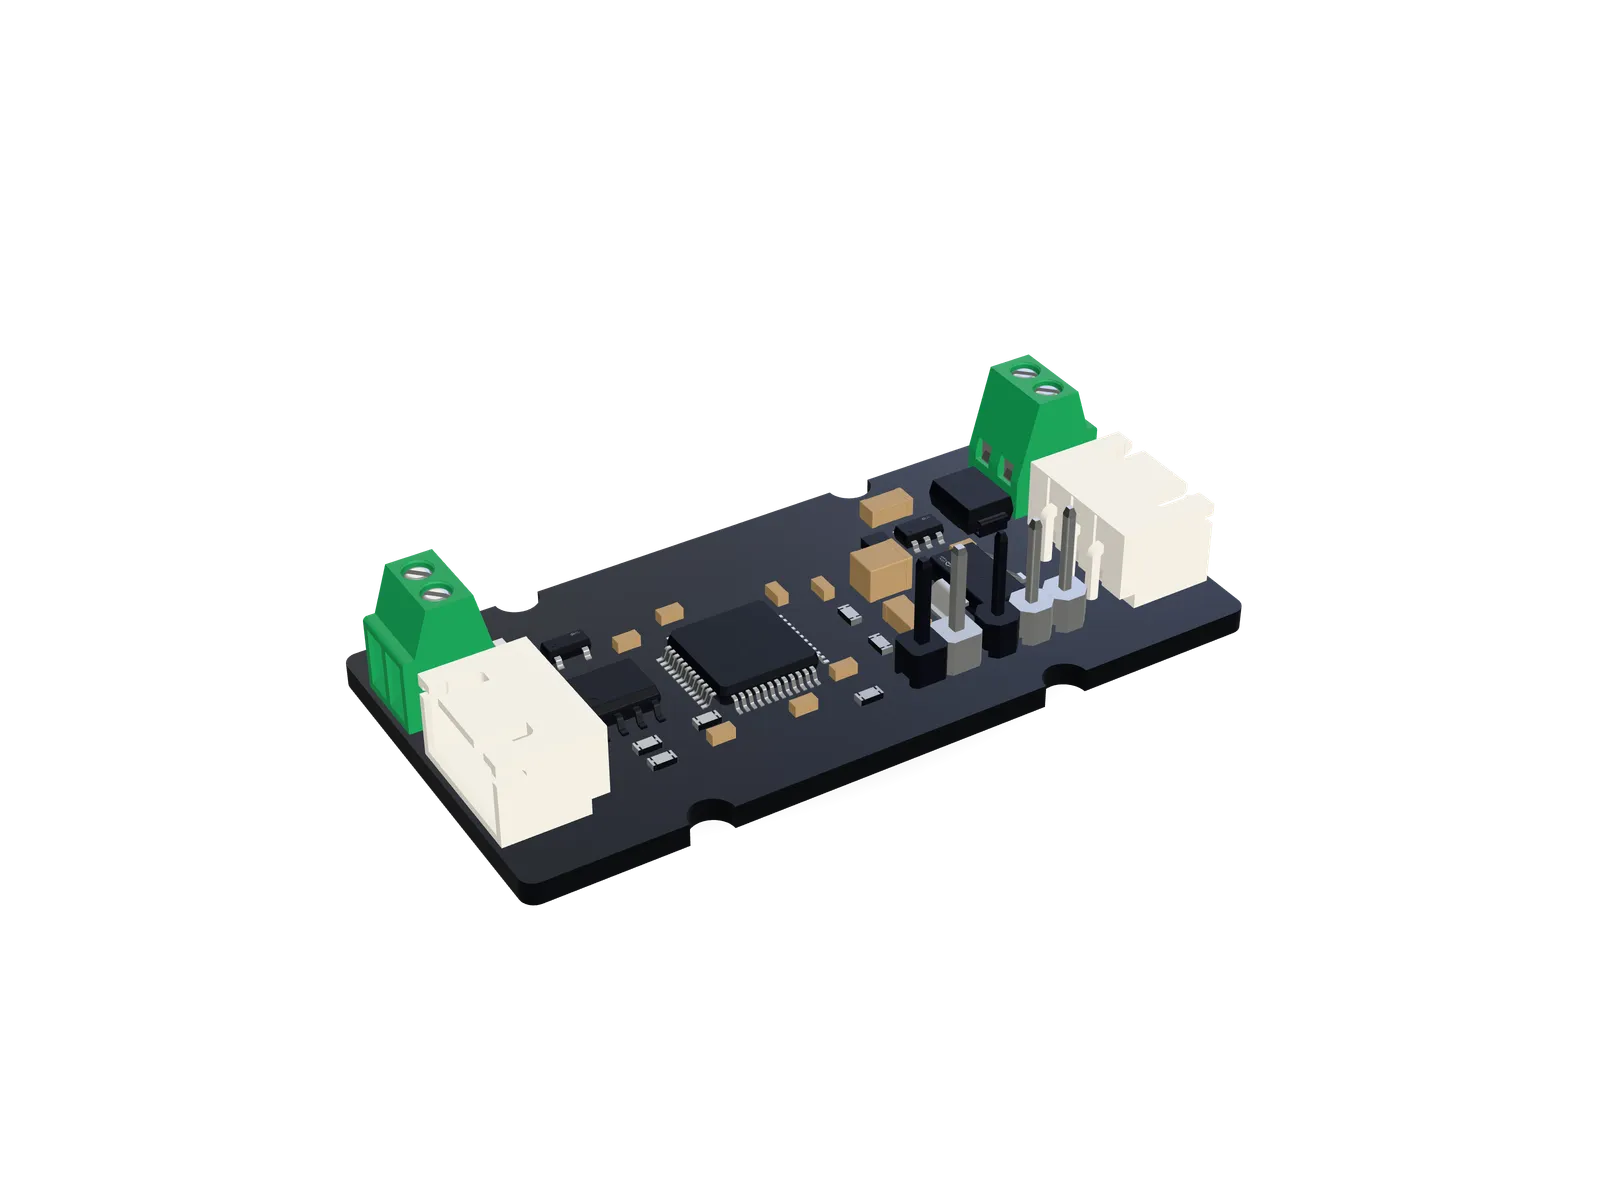
Tercio is a family of small modules for motion that share one CAN-FD bus. A Tercio S1 turns a stepper motor into a closed-loop servo axis, the Tercio FD connects the bus to your computer, and the Tercio IMU adds orientation on the same wires.
One twisted pair (CAN-H, CAN-L) plus GND runs from the adapter through every node. The two ends of the bus are terminated with 120 Ω: the adapter (built in) and the last node. Each S1 also needs its own 12–28 V supply.
Every driver on the bus has a node ID from 1 to 127. The computer sends commands through the Tercio FD to one node or to all of them at once, and each driver streams its state back. The adapter only forwards frames, so the same bus works with the browser control panel, Python, an Arduino, or your own code.
A stepper motor with an encoder magnetBipolar, four wires, with a diametric magnet on its rear shaft. S1-ready motors have it fitted; otherwise see Mounting.
A Tercio FD and a USB-C cableYour computer’s way onto the bus.
A 12–28 V DC supply24 V is a good choice. Each S1 needs power; the bus does not carry it.
CablesCAN cable from the adapter to the first driver, a motor cable and a power lead. The Starter Kit has the S1, the FD and the CAN cable.
A computerChrome or Edge for Tercio Control, or Python 3.
Units are turnsOn the wire, positions are turns of the encoder shaft, speeds turns/s, accelerations turns/s². Tercio Control and the libraries convert to degrees or radians for you.
Firmware v2, protocol v2These docs describe firmware v2 on the S1 and the FD. Protocol v2 does not talk to the first firmware: update both ends together. Tercio Control shows the version on each motor’s Diagnostics tab.